OK-Robot
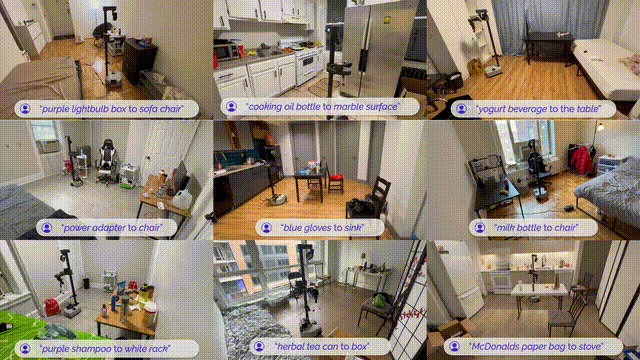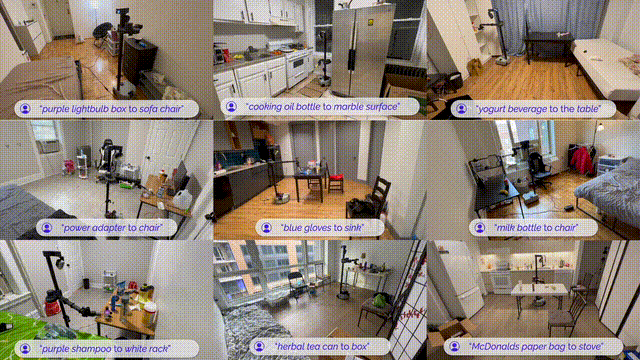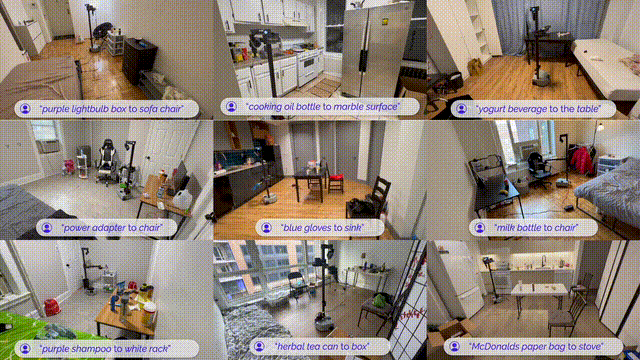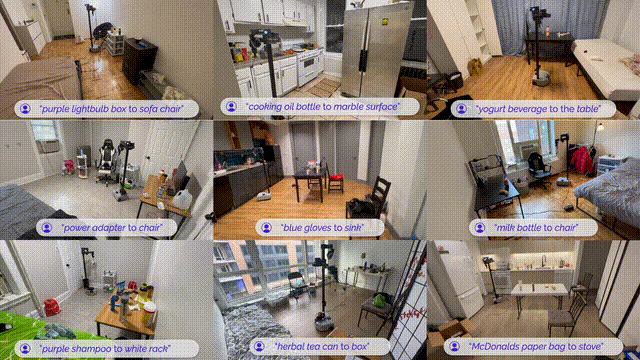
open, modular home robot framework for pick-and-drop anywhere. OK-Robot is an open framework for a modular system for zero-shot, language conditioned pick-and-drop tasks in arbitrary homes. OK-Robot accomplishes this with a modular design, using 3D VoxelMap for open-vocabulary navigation, AnyGrasp and LangSam for open-vocabulary grasping, and a dropping primitive for placing. You can simply unbox the target robot, install OK-Robot, give it a "scan" (think a 60 second iPhone video), and start asking the robot to move arbitrary things from A to B.
라이브러리
반응 (1)
비슷한 프로덕트
설명이 비슷한 순
Stack-chan
github.comOpen-source companion robot easy to assemble and customize
Foosbar
github.comMy autonomous foosball-playing robot
Dobb·E
dobb-e.comtowards home robots with an open-source platform
Robot Utility Models
robotutilitymodels.comopen-source robots working in new envs zero shot
K-Scale Labs (YC W24)
kscale.devOpen-Source Humanoid Robots